05 · Diffusion Policy and multimodal actions
Explain why averaging demonstrations can fail and how conditional denoising represents alternatives.
Prerequisites: Behavior cloning, Gaussian noise and sequence prediction.
Understand the mechanism
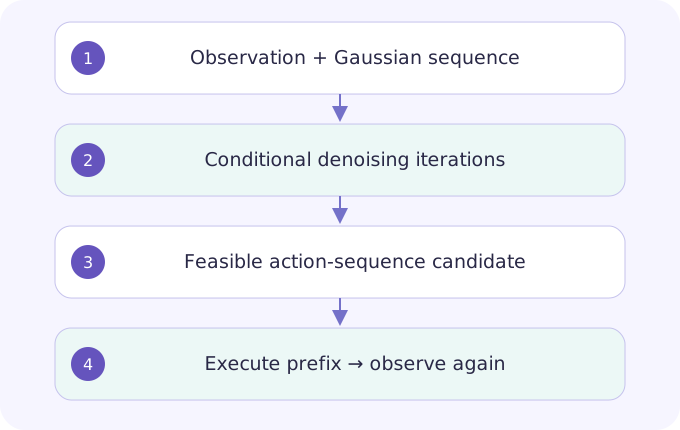
When a robot can go left or right around an obstacle, the average path may collide. A conditional diffusion policy represents an action distribution through iterative denoising instead of a single regression mean. The paper combines action-sequence prediction with receding-horizon execution. Sampling cost matters: compare quality under an actual inference deadline rather than counting denoising steps alone. Different samplers and schedules are not interchangeable without measurement.
Text / 原始公式
a_k = √ᾱ_k · a₀ + √(1−ᾱ_k) · ε
L = E[‖ε − εθ(a_k, k, o)‖²]
ε ~ N(0,I)
Study guide & lesson outline
LEARNING CONTRACTUnderstand → implement → investigate
Goal: explain the mechanism in this lesson, reproduce one example and test a failure case. Reading alone does not mark mastery.
- Understand: state assumptions, shapes/units and a counterexample.
- Implement: reproduce a numerical example and inspect boundaries.
- Investigate: compare one alternative under a matched budget.
Mechanism map & worked derivation
| Symbol | Meaning |
|---|---|
| a₀, a_k | Clean action sequence and noisy sequence at diffusion step k |
| ᾱ_k, o | Cumulative signal coefficient and conditioning observation |
- Two equally likely valid scalar actions are −1 and +1. Their squared-error regression optimum is 0, which may correspond to the obstacle.
- For clean
, and sampled , the noisy action is 0.8−0.3=0.5. This is forward corruption, not an executed motor command. - At 4 ms per model evaluation, 10 serial evaluations take 40 ms before preprocessing and transfer. A 20 ms deadline is already missed.
Build a synthetic two-route dataset and compare regression with a conditional sampler. Count obstacle intersections and mode coverage, not only MSE. Label this as a toy test, not a reproduction of manipulation benchmarks.
Original interview exercises & analysis
Answer aloud before revealing the analysis. Add assumptions, a counterexample and a test you would run.
Does stochastic generation guarantee diverse safe actions?
No. Training coverage, conditioning and sampler behavior matter; generated trajectories still need feasibility and collision checks.
Why predict longer than you execute?
A longer prediction supplies temporal context while a shorter executed prefix allows feedback. The best ratio depends on latency and disturbance rate.
Read the primary sources
Diffusion Policy ↗ · arXiv PDF ↗
Original Token Lab explanations and synthetic calculations; not measured robot performance. Source links checked 2026-10-25. Unversioned arXiv links may change; record a version for reproduction.